kaun atharva?

00 — the workshops

  1. a question
  2. my father owns a furniture workshop. i went there to watch.
  3. later i started making things there myself.
  4. i wanted a chair. nobody was going to buy me one. there was a broken one lying in the shop.
  5. my mama had a garage. he showed me how to weld.
  6. for a few months, it held.
  7. it broke again a few months later.
  8. i never got round to fixing it.
  9. a friend was building something at his desk. he did not explain much. i just watched.
  10. then i tried one on my own.
  11. 2018 · ultrasonic sensor, servo, dustbin lid

↓ ten years, in order

01 · 2018 — 2022

the first ones

an arduino, a breadboard, and a bag of parts i did not understand yet.

i watched videos and tried to copy them with the parts i had, which was never the parts they had.

2018 · age 11 · the first one

an ultrasonic sensor, a servo, and a dustbin lid.

distance ≈ 24 cm
  • ~2019

    Phone-controlled bulb

  • ~2019

    Mini piano

  • ~2019

    Wireless specs finder

  • ~2020

    Soundbar

  • 2021

    Bag weight distributor

  • ~2021

    The Santa that dispensed Fanta

    me and a friend were bored on christmas.

2021 a school bag that redistributes its own load. inspire award manak, government of india. ₹10,000.

my parents were there.

02 · 2022 — 2024

the silence

two years. i built nothing.

my preference list had mechanical and electrical on it. nothing else.

03 · 2024

the capacitor

at iit indore. i emailed prof. i.a. palani and asked if i could see his lab. he said yes.

that same day a machine had a faulty capacitor. someone asked if i could replace it.

i could. i had been doing that kind of work since i was twelve.

i have had a key to that lab ever since.

24/7 access. a place to sit. we still go to dinners together.

Power-harvesting army boots — laser-textured TENG — An army boot that generates its own electricity from walking. A triboelectric nanogenerator in the sole is laser-textured at 355 nm to raise its output, then rectified and stored to run GPS and RFID for locating and identifying soldiers — with no battery to change. Ten pairs were built and delivered to ARDE, Pune.
2021–24

Power-harvesting army boots — laser-textured TENG

An army boot that generates its own electricity from walking. A triboelectric nanogenerator in the sole is laser-textured at 355 nm to raise its output, then rectified and stored to run GPS and RFID for locating and identifying soldiers — with no battery to change. Ten pairs were built and delivered to ARDE, Pune.

DRDO / ARDB-funded, three years, led by Prof. I.A. Palani at IIT Indore. My first project in that lab: the impedance-matching and rectification circuit, which improved charging efficiency by 54%. Patent filed.

2025

Gait-analysis shoes for early Alzheimer’s detection

A wearable shoe embedded with TENG sensors to monitor gait abnormalities.

I stopped for three reasons: my own expertise ceiling at the time, TENG not showing promise, and training data that would have needed hospital access to patients.

Micromouse — A maze-solving robot.
2024–25

Micromouse

A maze-solving robot.

2025

Morphobot — a drone that lands and drives away

flying is expensive. if the ground is drivable, don’t fly.

A vehicle that flies to a site, lands, folds its rotor arms down and drives on the rotor guards as wheels — then reaches into rubble with a 4-axis arm actuated by shape memory alloy and steered by hand gestures. Built for disaster response: search from the air, work on the ground.

Two prototypes. Mechatronics & Instrumentation Lab, IIT Indore, under Prof. I.A. Palani. With Soham Mondal and Tejal Uplenchwar.

2025

NoGPS autonomous drone — ISRO Robotics Challenge

An autonomous aerial drone for Martian-surface operation: real-time terrain mapping, safe-spot detection, GPS-independent landing.

IROC 2025. There is a folder in my archive named “fails”. It has six videos in it.

2024–25

Line follower → patrolling bot

the makerspace course asked for a line follower. we had to add one feature of our own.

A line-following robot that streams live camera footage back to a PC. An SOS button on the device notifies the control centre and puts the bot into a 360° rotation so it can be found.

First-year Makerspace course project, IIT Indore.

2025

Custom ESP32 flight controller

A custom flight-controller PCB integrating MPU6050 IMU, magnetometer and optical flow sensor. EKF sensor fusion achieving a 25-minute stable hover in GPS-denied conditions.

STARC Lab, IIT Indore.

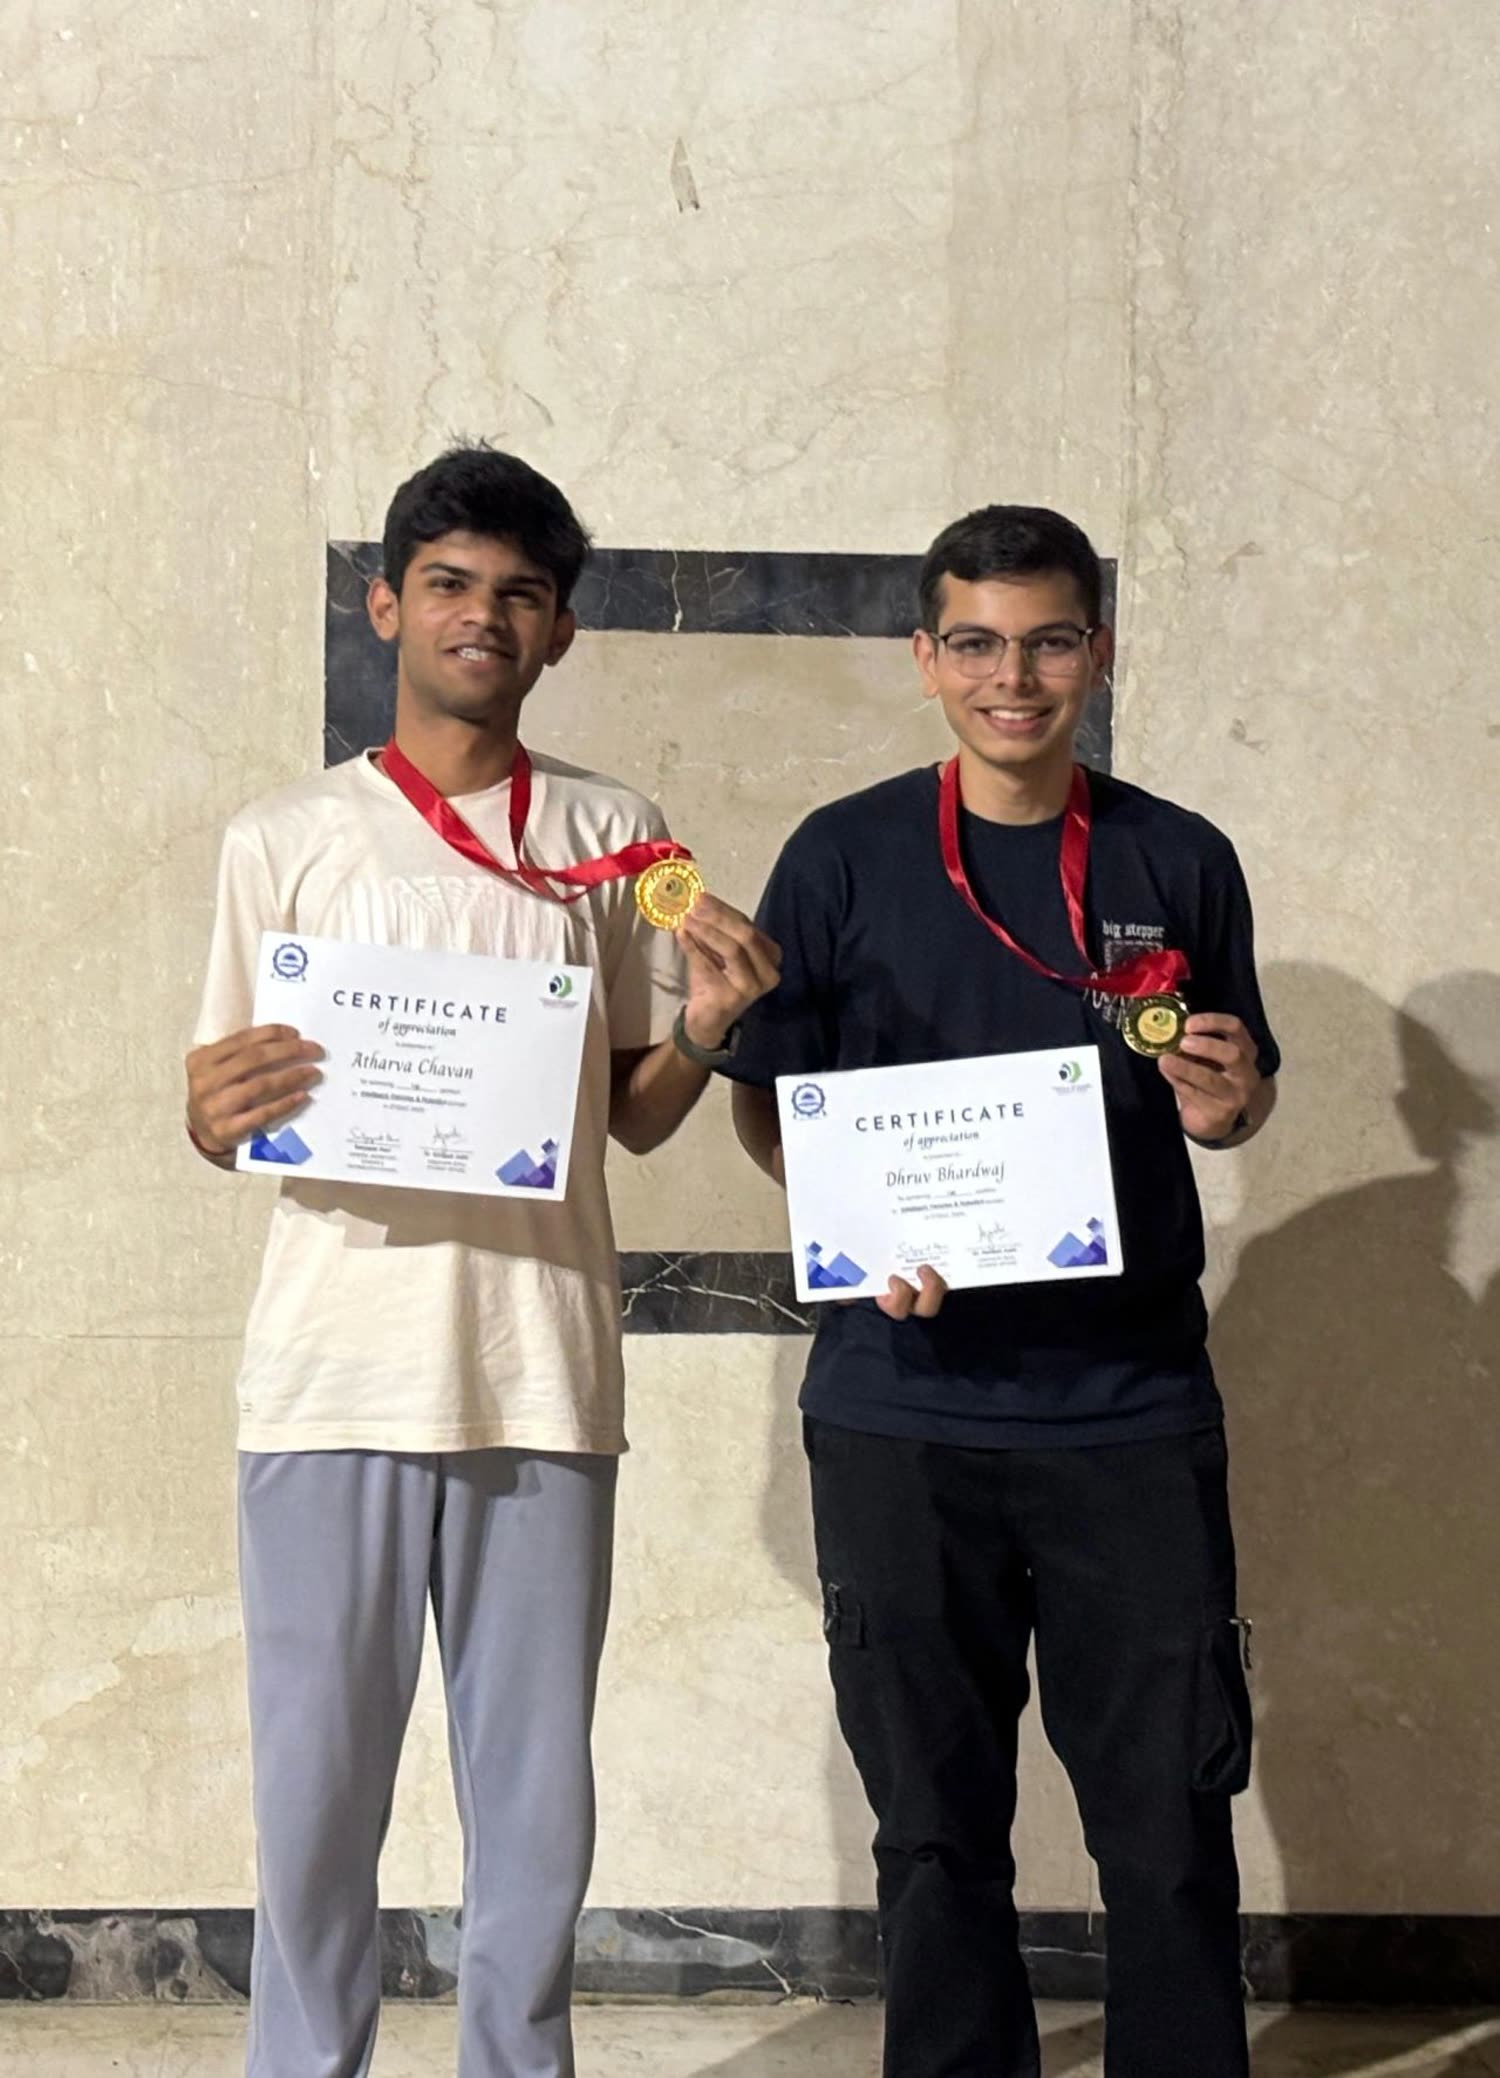
Gold Medal — IITISoC, Robotics — Gold in the Robotics domain of the IIT Indore Summer of Code, for the machine management system.
2025 · award

Gold Medal — IITISoC, Robotics

Gold in the Robotics domain of the IIT Indore Summer of Code, for the machine management system.

2025–

Universal Machine Management System (RFID access control)

Full-stack access-control infrastructure across five lab machines: ESP32 + MFRC522 RFID nodes with relay actuation, an automated card dispenser, an RPi 5 issuing station, and a Firebase backend with a real-time dashboard.

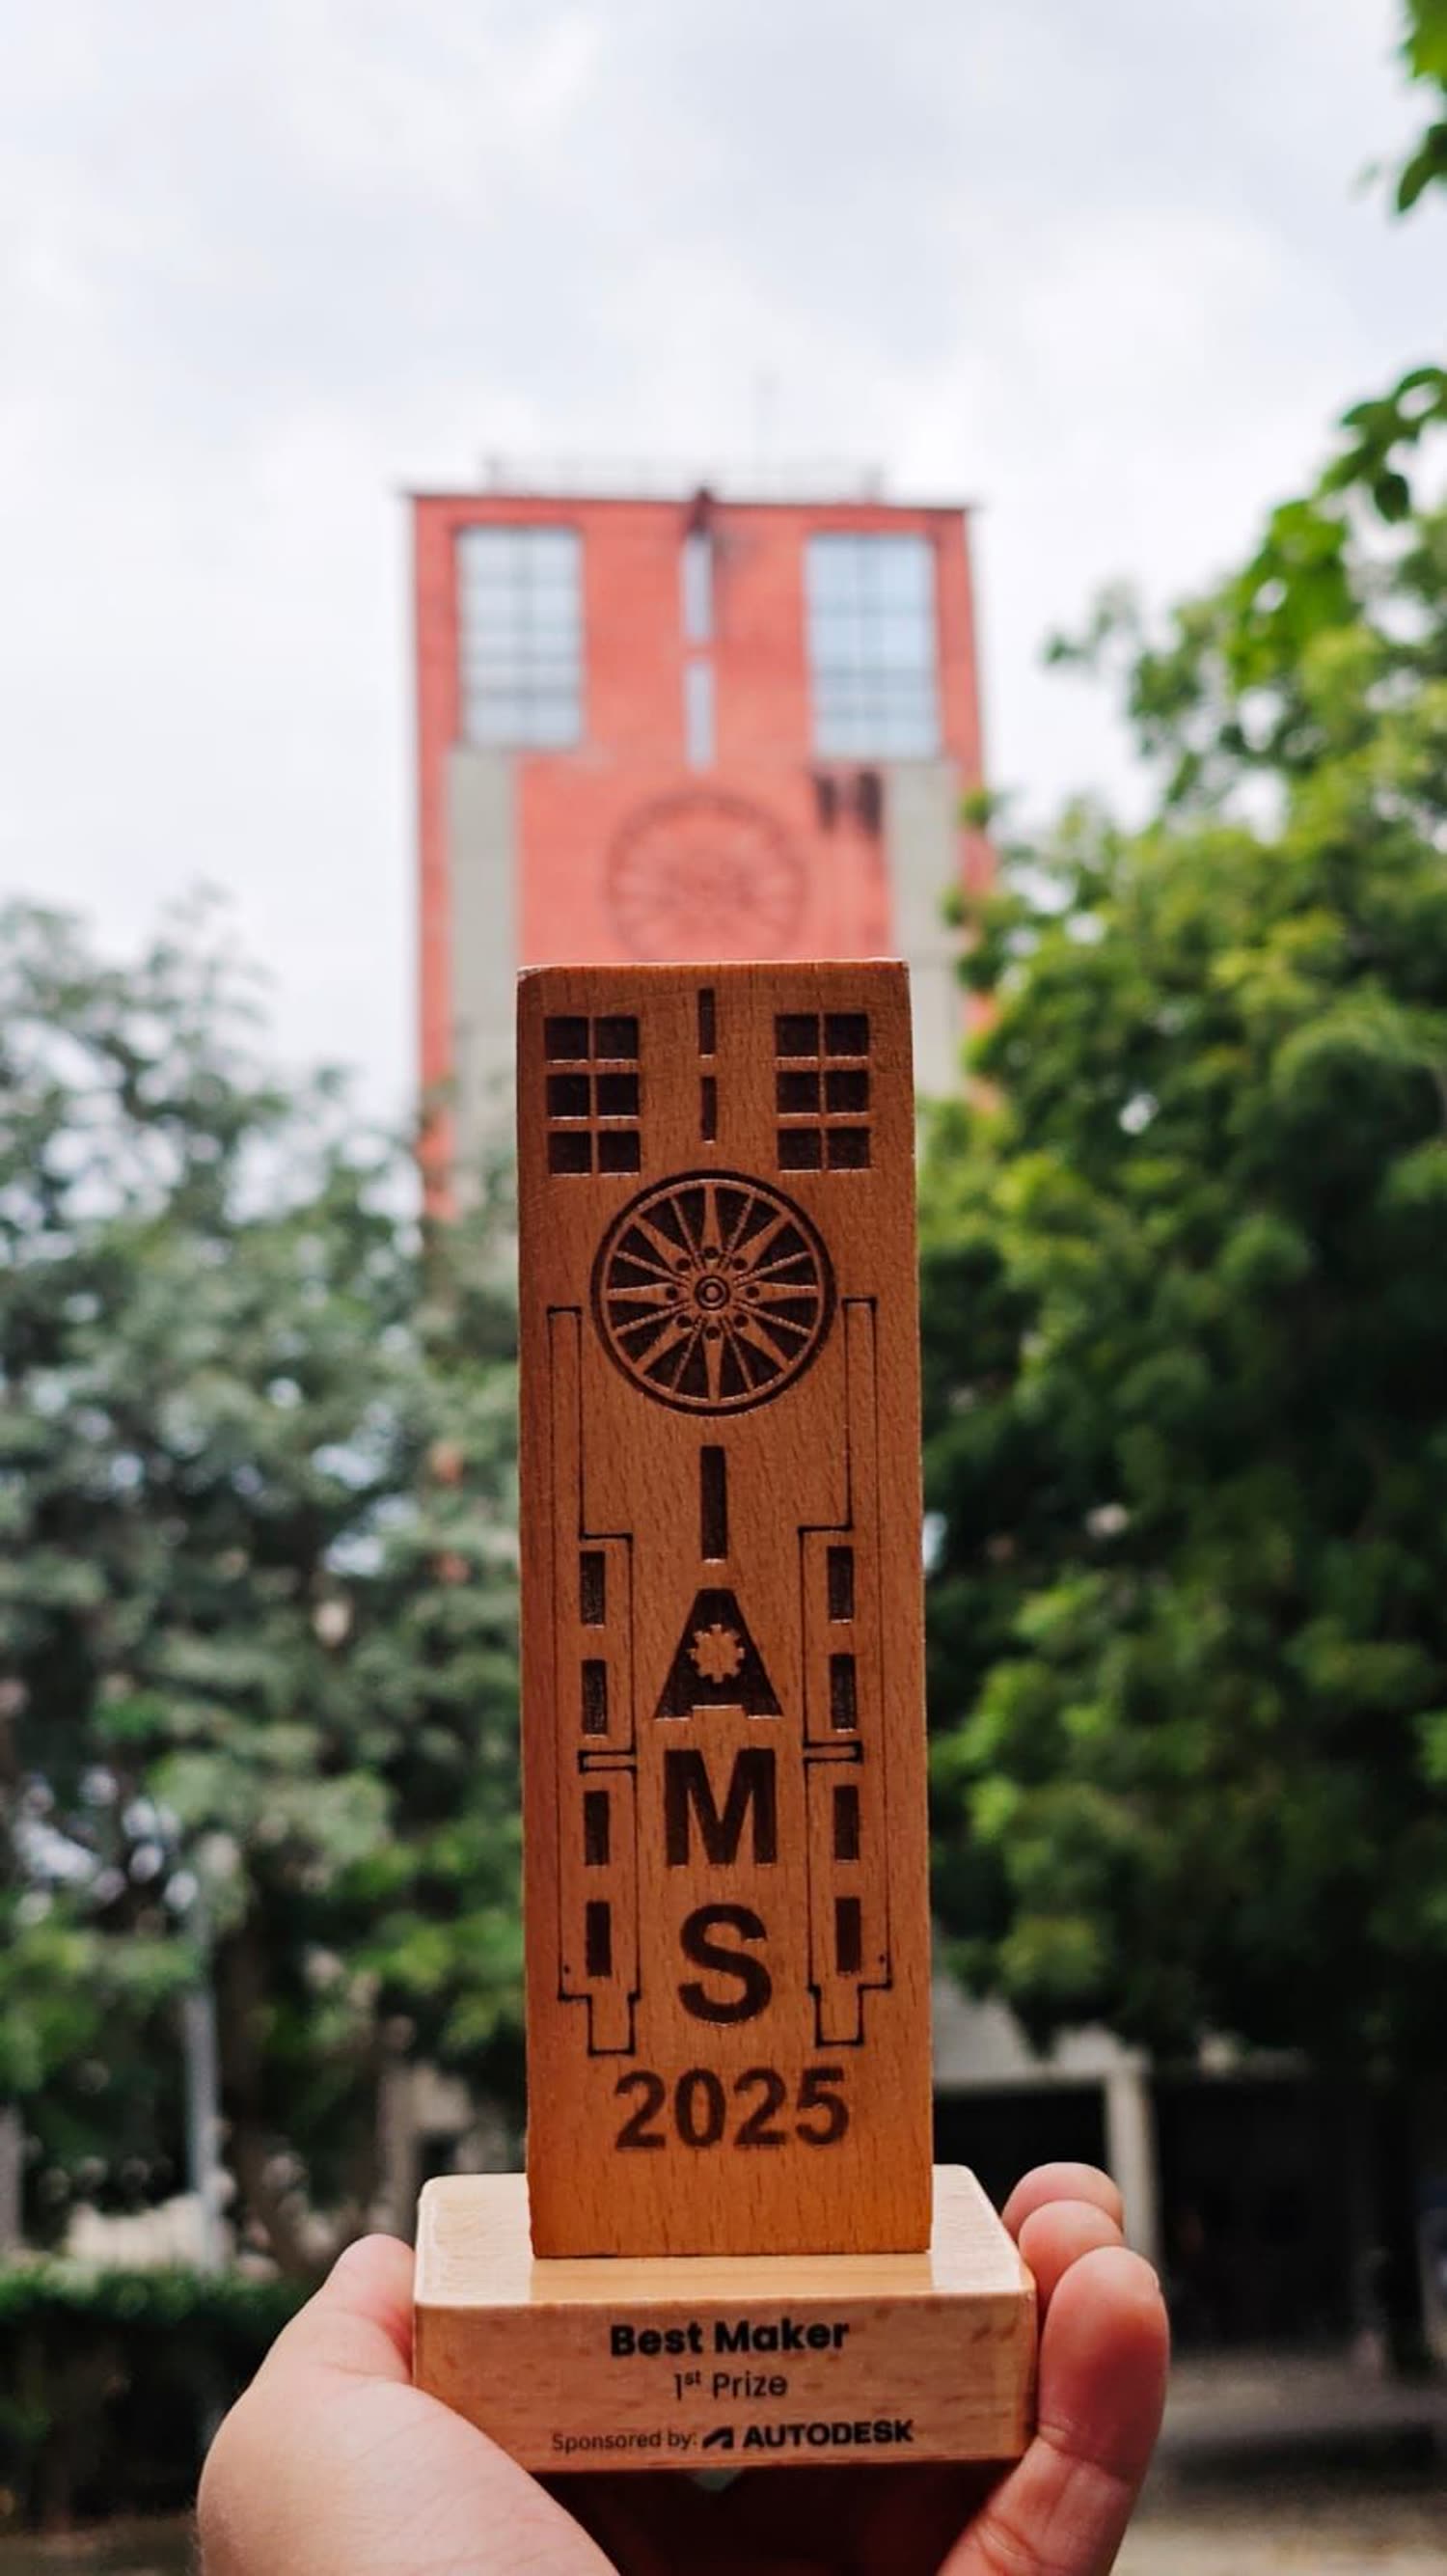
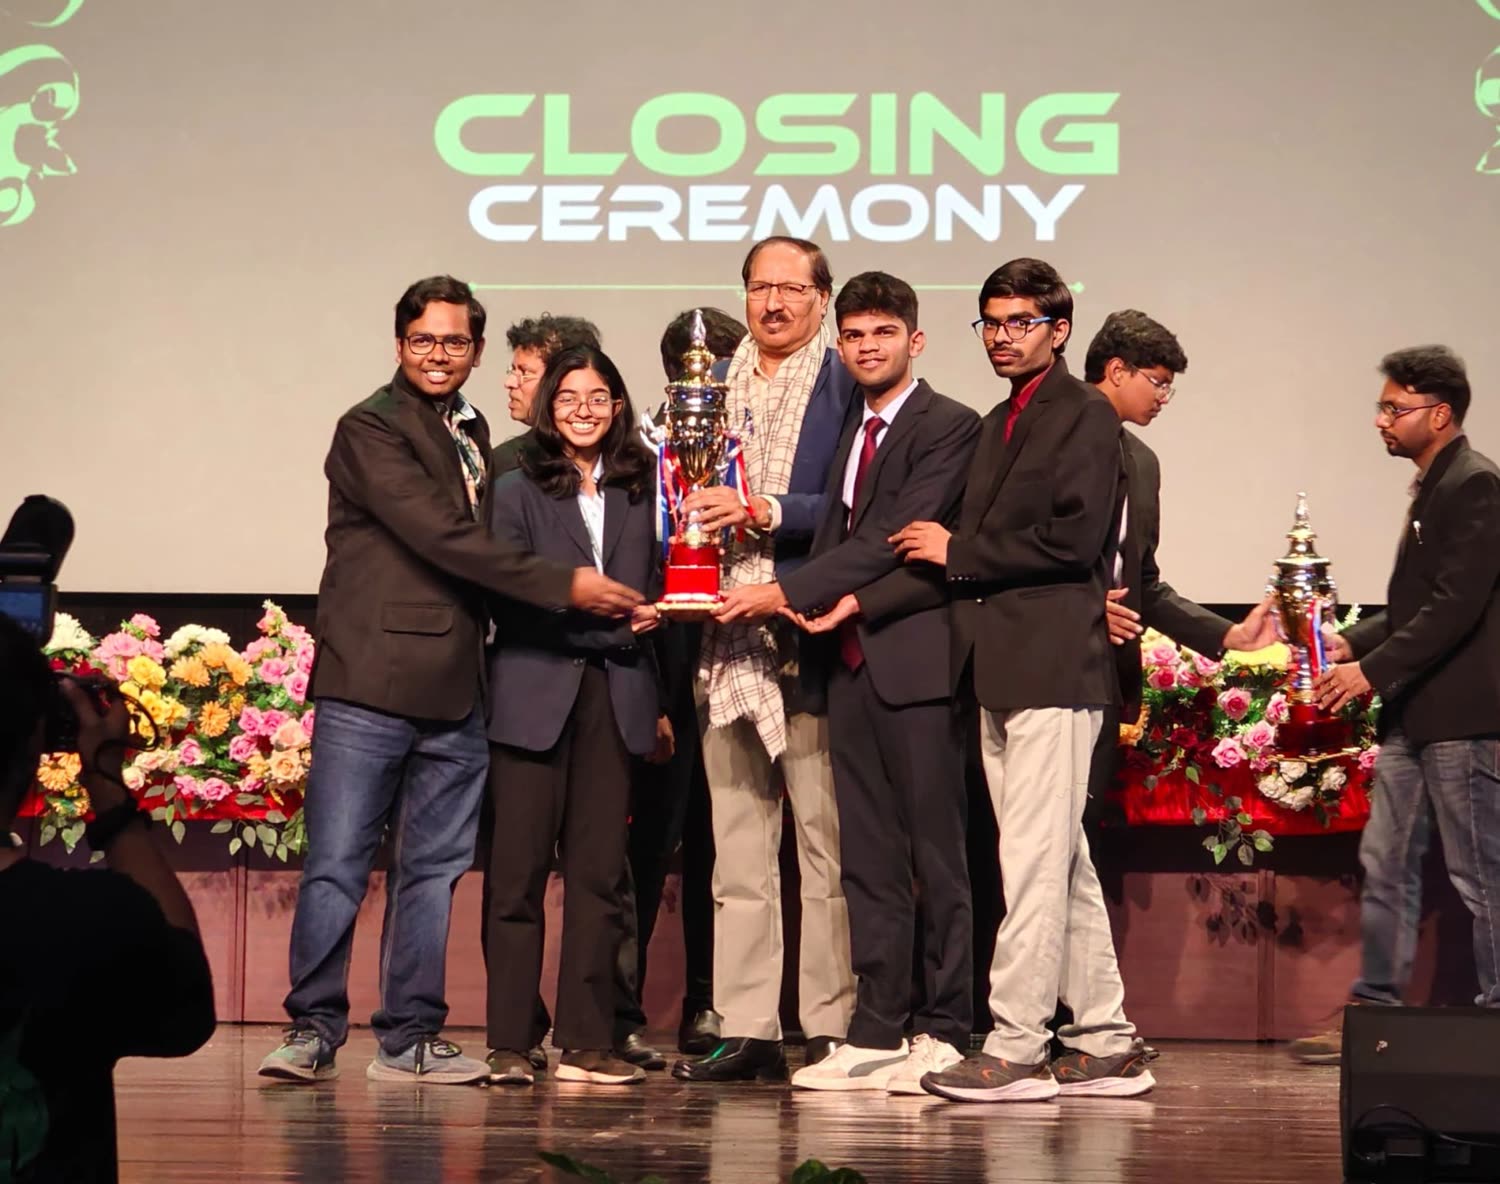
IITISoC Gold Medal. Grand Innovation & Best Maker Award, IAMS 2025, ₹62,500. Patent in progress. Operational in Tinkerers’ Lab, IIT Indore.

Grand Innovation & Best Maker Award — IAMS 2025 — Both the Grand Innovation Award and the Best Maker Award at the Indian Academic Makerspaces Summit, with a cash prize of ₹62,500, for the machine management system.
2025 · award

Grand Innovation & Best Maker Award — IAMS 2025

Both the Grand Innovation Award and the Best Maker Award at the Indian Academic Makerspaces Summit, with a cash prize of ₹62,500, for the machine management system.

IAMS 2025, IIT Gandhinagar.

2025

Eternal — autonomous warehouse inventory robot

A Jetson Orin Nano-powered AMR: ROS2/Nav2, RPLidar A1 SLAM, AMCL localization, four-channel ultrasonic obstacle avoidance. ±7 cm horizontal, ±0.02 cm vertical. Belt-driven Z-axis scanning 200–1800 mm with 100% QR detection.

Bronze Medal, Inter IIT Tech Meet 14.0, among all IITs.

3rd Position — Inter IIT Tech Meet 14.0, Eternal — Bronze in the Eternal problem statement — the autonomous warehouse inventory robot — competing against teams from every IIT.
2025 · award

3rd Position — Inter IIT Tech Meet 14.0, Eternal

Bronze in the Eternal problem statement — the autonomous warehouse inventory robot — competing against teams from every IIT.

Inter IIT Tech Meet 14.0, held at IIT Patna.

2026

Aqualoop — in-pipe water monitoring and selective recycling

A module that fits between any two pipes and powers itself from the water running through it. A micro-hydro turbine charges the electronics; pH, TDS and turbidity sensors feed a polynomial regression on the microcontroller to produce a live water quality score. At a building inlet it verifies the incoming supply and flags contamination. At the outlet it drives smart diverter valves, splitting used water into a recycling tank or the septic line — instead of treating everything as one waste stream.

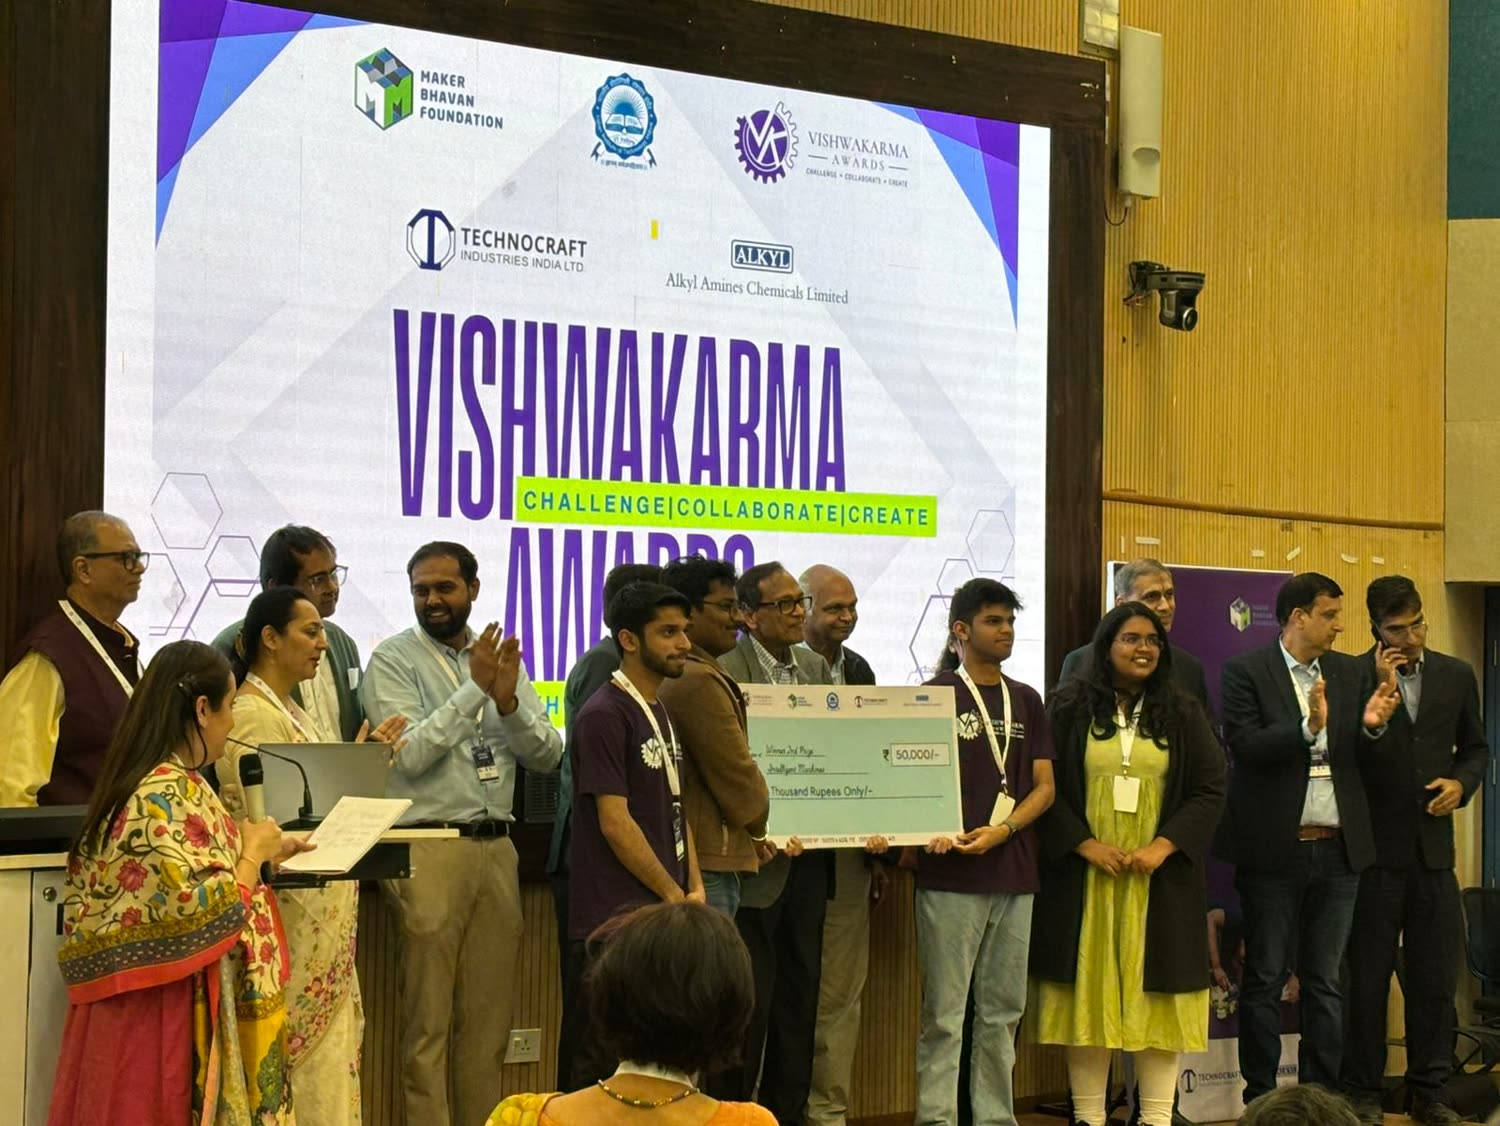
Second place, Vishwakarma Awards 2026 — among 1,054 teams. ₹80,000. Team of 5.

2nd Prize — Vishwakarma Awards, Intelligent Machines — Second place among 1,054 teams, with a cash prize of ₹80,000, for Aqualoop — the in-pipe water quality monitoring and selective recycling system.
2026 · award

2nd Prize — Vishwakarma Awards, Intelligent Machines

Second place among 1,054 teams, with a cash prize of ₹80,000, for Aqualoop — the in-pipe water quality monitoring and selective recycling system.

Awarded by the Maker Bhavan Foundation. Team lead.

2025–26

Low-speed wind tunnel with LED-based PIV

A low-cost tabletop wind tunnel with transparent test section and custom contraction–diffuser geometry, plus an LED-based PIV alternative using OpenCV optical flow to visualise velocity fields.

2026

Ball balancing bot — a Stewart platform that will not let a ball fall off

A 3RRS parallel manipulator that keeps a ball balanced at the centre of a tilting plate. An overhead Pi Cam finds the ball by HSV threshold and blob centroid, a PID controller works out the tilt needed to correct it, inverse kinematics converts that tilt into three servo angles, and the loop repeats fast enough that the ball never gets away.

AA216 Flight Mechanics & Classical Control, IIT Indore. Group project of five.

the course deck

2026

Self-powered IoT fault detection — TENG + STL–CNN–LSTM

A deep-learning fault detection pipeline for rotating machinery using TENG sensors as self-powered vibration transducers. STL decomposition across seven fault classes, 1D-CNN feature extraction, LSTM temporal modelling. 98.57% accuracy — beating oscilloscope (97.31%) and accelerometer (95.83%) baselines.

Jan–May 2026

Large-format cartesian cement 3D printer

1000×1000×600 mm. SFU1605 ball-screw X/Y, C-beam Z-axis, hopper-auger extrusion, NEMA 23 steppers, Arduino Mega + RAMPS 1.4. End-to-end component sourcing, Fusion 360 CAD, and hardware integration.

Sold to and deployed in a research laboratory.

Feb 2026

Autonomous & glove-controlled collaborative robot

Two ways to drive an Addverb Syncro 5 six-axis cobot. Say “pick up the red bottle” and an LLM extracts the intent, a depth camera sweeps the workspace, YOLO closed-loop visual servoing centres the target, and the arm grasps and retracts unaided. Or wear an ESP32 sensor glove and fly it by hand, seven gestures classified online at ~20 Hz.

Team of 8. Featured on Addverb Technologies’ official blog.

Research Intern — Centre for Mechatronics, IIT Kanpur — Joined the Centre for Mechatronics at IIT Kanpur as a research intern, sponsored by NPTEL. This is where DUNE was built.
2026 · internship

Research Intern — Centre for Mechatronics, IIT Kanpur

Joined the Centre for Mechatronics at IIT Kanpur as a research intern, sponsored by NPTEL. This is where DUNE was built.

2026

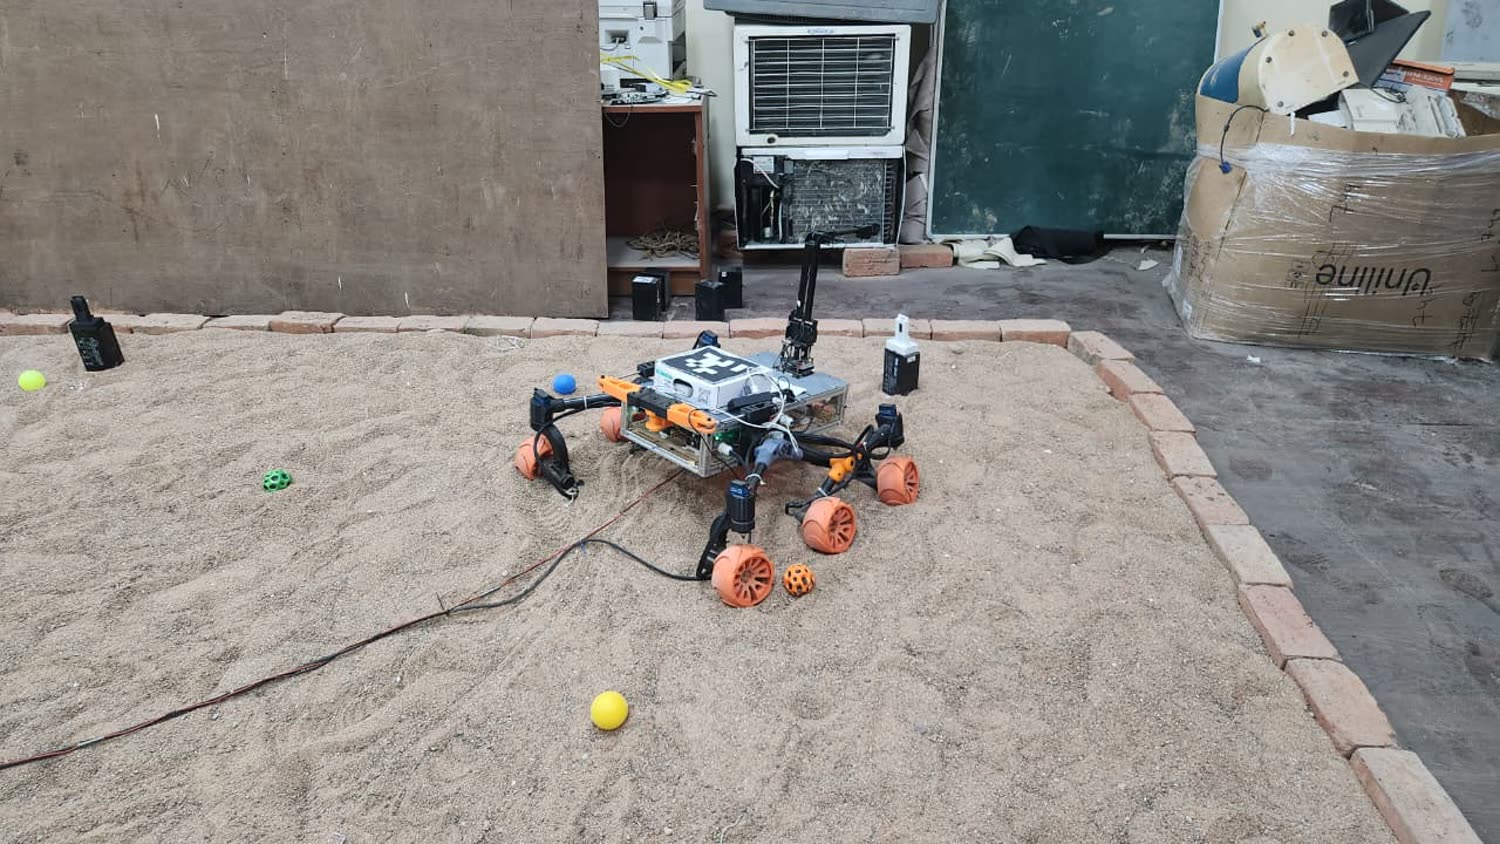
DUNE — Dual UWB Navigation Engine

UWB-based indoor localization for a six-wheeled rocker-bogie rover in GPS-denied environments. Sub-7 cm positional accuracy in a 2×2 m arena via two-anchor two-way ranging. Dual-tag heading estimation with EKF fusion of UWB, wheel odometry and IMU.

IEEE paper submitted. Open-source library plus hardware. Centre for Mechatronics, IIT Kanpur.

05 · now

the open question

2026–

GPS-denied UWB drone–rover cooperative navigation

A four-phase cooperative autonomy architecture: a drone autonomously deploys UWB anchors for centimetre-level rover localization. Onboard EKF fuses UWB, optical flow and IMU; a MAVLink/ROS2 bridge carries drone–rover comms.

First-author oral, NSSS 2026 (ISRO-sponsored) — selected among 40 students nationwide. Sub-10 cm on live hardware.

right now: aqualoop, the machine management system, and a rover that can land a drone on itself and find its own way, all on uwb.

that last one is not working yet.

none of it was only me. see who ↓

the first door

  • Harshit Chandakchildhood friend — showed me electronics

family

  • My fatherthe furniture workshop
  • My mamathe garage, and the welding

professors

  • Prof. I.A. PalaniMechatronics Lab, IIT Indore
  • Prof. Ashish DuttaCentre for Mechatronics, IIT Kanpur
  • Prof. Abhirup DattaSTARC Lab / Dean R&D, IIT Indore

mentors & seniors

  • Adersh MIIT Kanpur
  • Rajat VishwakarmaIIT Indore
  • Hrishikesh JawaleIIT Indore
  • Anand NambiarIIT Indore
  • Tejas BhavekarIIT Indore

the mechatronics lab

  • Diksha JaurkerPhD, Mechatronics Lab
  • Anshu Sahunow Professor, SRM University
  • Arpit Singhnow postdoc, Dalhousie University
say something

leave a note

click anywhere on the board. drag it wherever you like.

click to add the first note